 Download PDF
ABSTRACT
This study applies the Natural Transform Iterative Method (NTIM) and Homotopy Perturbation Method (HPM) to approximate solutions for fractional order two-dimensional partial differential equations, focusing on the Zakharov–Kuznetsov equation. It uses Caputo fractional derivatives and Mathematica for efficient computation, producing rapidly convergent series solutions. Rigorous comparisons with existing methods affirm the method’s robustness and efficiency in solving higher-dimensional fractional order equations, demonstrating its computational efficacy and practical utility in addressing complex mathematical challenges posed by fractional order systems.
Keywords: Homotopy Perturbation Method: Caputo Derivative; Natural Transform Iterative Method; Natural Transform; Analytical Techniques
INTRODUCTION
Fractional calculus (FC), which originated in the era of Newton, has recently garnered significant scholarly interest. Over the past three decades, notable advancements in scientific and engineering applications have emerged within the domain of FC. The fractional derivative concept has evolved to address the intricacies associated with heterogeneous phenomena. Fractional differential operators prove effective in capturing the intricate behavior of complex media undergoing diffusion processes. Serving as an indispensable tool, differential equations of arbitrary order facilitate a more convenient and accurate illustration of numerous problems. The rapid progress in mathematical techniques, coupled with advanced computer software, has prompted researchers to delve into generalized calculus, enabling them to articulate their perspectives when analyzing intricate phenomena.
Fractional calculus, an extension of integer-order calculus, was historically perceived as a purely mathematical discipline with no tangible applications in the real world. However, recent advancements have disproven this notion, showcasing the utility of fractional calculus in various practical scenarios. Applications include modeling sound wave propagation in rigid porous materials, analyzing ultrasonic wave propagation in human cancellous bone, characterizing the viscoelastic properties of soft biological tissues, and addressing the path tracking problem in autonomous electric vehicles [1-4]. The focal point of numerous studies lies in differential equations of fractional order, given their frequent utilization in diverse fields such as electromagnetic phenomena, electrochemistry, acoustics, material science, physics, viscoelasticity, and engineering [5-9]. These problems are notably more intricate compared to integer-order differential equations. Due to the inherent complexities of fractional calculus, a significant portion of fractional order differential equations lacks exact solutions. Consequently, researchers extensively employ approximate methods for solving these equations [10-14]. Recent methods for approximating solutions to fractional order differential equations include semi-analytical techniques [15-26].
This study extends the NTIM and HPM formulations to fractional order partial differential equations in two dimensions. In particular, examples of the fractional version of the Zakharov-Kuznetsov equations, or F ZK( ), are used to demonstrate the extended formulation.
The provided equation involves the parameter β, which characterizes the fractional derivative theory with a restriction of (0 < β ≤ 1). The constants a˘, ˘b and c˘ are arbitrary, whereas ˜p, ˜q, ˜r ̸= 0 are non-zero integers that affect the behavior of weakly nonlinear ion-acoustic waves in a plasma with cold ions and hot isothermal electrons under a uniform magnetic field. Numerous researchers have successfully addressed the the FZK equation, employing various methodologies, as outlined in recent studies [27-31]. These diverse approaches highlight the breadth of techniques applied to solve this equation, underscoring the significance of understanding its solutions in the context of plasma physics. There are six sections in this study. Basic concepts and characteristics from fractional calculus are given in Section 2. The study of NTIM and HPM for two-dimensional FPDEs is the main topic of Section 3. The FZK (2, 2, 2) and FZK (3, 3, 3) equation’s second-order approximation solutions are shown in Section 4, where the temporal fractional derivatives are specified in the Caputo sense. In Section 5, the second-order approximation solutions produced by the suggested techniques are contrasted with the results of the Perturbation-Iteration Algorithm (PIA) and the third-order Variational Iteration Method (VIM). The suggested approaches show better outcomes in every case.
Basic Definitions
Here, we explore two key ideas that are fundamental to the present framework: The Fundamentals of Fractional Calculus and the Natural Transform [32].
Definition
Using the Riemann-Liouville technique , the fractional i integral for a function
Definition
According to the Caputo method, the fractional-order derivative is as follows
Definition
The natural transform of ψ(t) is defined as
Where δ, u > 0 are the transform variables.
Definition
If R (δ, u) is ψ(t) natural transform, then ψ(t) inverse natural transform is described as follows:
The integral is represented as δ = a + bι in the complex plane along δ = c, where c ϵ R.
Definition
Given is the nth derivative of the natural transform of ψ(t)
Basic Procedure of Methods
Natural Transform Iterative Method
Take into consideration FDE of the following form [33]:
where the Caputo fractional derivative of order , and are represented by . and , respectively, stand for the linear and non-linear functions. The function is known. The corresponding initial condition are given as follows
Using the natural transform, equation (6) has undergone a natural transformation.
Using the definition, Equation (8) can be represented as
When we arrange equation (9), we obtain
When computing the NTIM solution, is extended as
and the non-linear term is defined as
Using Equation (11) and Equation (12) in Equation (10), we obtain
Utilizing the recursive relationship
Using equation (14) as an inverse natural transform, we get
After adding up all the components, the approximate solutions to equations (6) and (8) using NTIM are given as follows
Bhalekar and Daftardar-Gejji assert that NTIM convergence is equal to NIM convergence [34].
Homotopy Perturbation Method
Take the following nonlinear differential equation to illustrate the operation of HPM:
with the boundary conditions
is a basic differential operator, is a boundary operator, is a well known analytic function, and is the domain boundary for .
The operator is decomposed into two pieces, and , where is linear and is nonlinear. Hence, Equation (17) may be expressed as follows:
He [35] built a homotopy that meets the condition,
or
where which is referred to as the homotopy parameter, and is the initial approximation of the function (17). Hence, it concludes that
and the procedure of moving from 0 to 1 is identical to that of from to . This is known as deformation in topology, and are called homotopic. Using the perturbation approach, and assuming that is a small parameter, we may suppose that the solution of (20) or (21) can be written as a series in , as shown below
when , (20) or (21) corresponds to (19) and becomes the approximate solution of (19), i.e.,
The convergence rate of the series (24) is dependent on in the majority of situations.
Solving Time Fractional FZK (2, 2, 2)
Examine the following equation and its accompanying initial conditions.
A precise solution to equation (25) for ,
where is an arbitrary constant.
Application of NTIM
Applying natural transform on Equation (25), we get
By applying the differentiation property of the natural transform to Equation (27), we obtain the following result
By applying the inverse natural transform to Equation (28), we obtain
Utilizing the recursive relation from Equation (15),
By using the software Wolfram Mathematica 13.2, the solution components are obtained as
By combining the components, the second-order approximate NTIM solution is expressed as.
Application of HPM
Applying the HPM formulation outlined in Section 3, we obtain
Zero-order component:
First-order component:
Second-order component:
The solutions for the aforementioned components are as follows:
By combining the components, the 2nd order approximate HPM solution is presented as:
Solving Time Fractional FZK (3, 3, 3)
Consider the following equation
The exact solution of equation (39) for , is
Application of NTIM
Applying natural transform on Equation (39), we get
By applying the differentiation property of the natural transform to Equation (41), we obtain the following result
By applying the inverse natural transform to Equation (42), we obtain
Utilizing the recursive relation from Equation (15)
By using the software Wolfram Mathematica 13.2, the solution components are obtained as
Combining these elements, the second-order approximate NTIM solution is formulated as follows:
Application of HPM
Utilizing the HPM formulation outlined in Section 3, we obtain Zero-order component:
First-order component:
Second-order component:
The solutions of above components are as follows:
Combining the components, the 2nd order approximate HPM solution is given as
RESULTS AND DISCUSSION
The FZK equation has been used to test the NTIM and HPM formulations; Mathematica 13.2 was used for the majority of the computational effort. Tables 1 and 2 present a comparison between the outcomes of the proposed method’s second-order approximation for the FZK (2, 2, 2) equation and the third-order approximations derived from the VIM and the PIA, respectively. The FZK (2, 2, 2) equation’s exact and approximate solutions, as determined by the suggested method, are plotted in three dimensions in Figures 3-4. Similarly, Figures 9 and 10 depict three-dimensional graphs comparing the exact and approximate solutions for the FZK (3, 3, 3) equation. In contrast, Figures 7 and 8 display two-dimensional illustrations of the FZK (3, 3, 3) equation at different β values, while Figures 1 and 2 show two-dimensional plots of the approximate solutions for the FZK (2, 2, 2) equation across varying β values. The two-dimensional graphics show that as β approaches 1, the approximate solutions become more similar to the exact solutions. The suggested method accurately approximates solutions for various configurations of the FZK problem, as evidenced by its convergence. Visual comparisons demonstrate the method’s ability to handle higher-order equations and variable parameters, indicating its promise for solving complicated differential equations.
| NTIM Error | HPM Error | PIA Error [36] | ||||||
|---|---|---|---|---|---|---|---|---|
| 0.1 | 0.1 | 0.2 | 5.20963×10⁻⁵ | 5.20977×10⁻⁵ | 5.25222×10⁻⁵ | 4.25938×10⁻⁷ | 4.24472×10⁻⁷ | 3.85217×10⁻⁷ |
| 0.1 | 0.1 | 0.3 | 5.18325×10⁻⁵ | 5.18358×10⁻⁵ | 5.24703×10⁻⁵ | 6.37842×10⁻⁷ | 6.34545×10⁻⁷ | 5.75911×10⁻⁷ |
| 0.1 | 0.1 | 0.4 | 5.15695×10⁻⁵ | 5.15753×10⁻⁵ | 5.24185×10⁻⁵ | 8.49036×10⁻⁷ | 8.43176×10⁻⁷ | 7.65359×10⁻⁷ |
| 0.6 | 0.6 | 0.2 | 1.15981×10⁻³ | 1.15982×10⁻³ | 1.15808×10⁻³ | 1.72413×10⁻⁶ | 1.73295×10⁻⁶ | 4.66337×10⁻⁵ |
| 0.6 | 0.6 | 0.3 | 1.16059×10⁻³ | 1.1606×10⁻³ | 1.15799×10⁻³ | 2.59286×10⁻⁶ | 2.61268×10⁻⁶ | 6.86056×10⁻⁵ |
| 0.6 | 0.6 | 0.4 | 1.16137×10⁻³ | 1.1614×10⁻³ | 1.1579×10⁻³ | 3.46604×10⁻⁶ | 3.50126×10⁻⁶ | 8.98263×10⁻⁵ |
| 0.9 | 0.9 | 0.2 | 1.26485×10⁻³ | 1.26484×10⁻³ | 1.26462×10⁻³ | 2.23227×10⁻⁷ | 2.15846×10⁻⁷ | 5.12131×10⁻⁴ |
| 0.9 | 0.9 | 0.3 | 1.26501×10⁻³ | 1.265×10⁻³ | 1.26468×10⁻³ | 3.29329×10⁻⁷ | 3.12727×10⁻⁷ | 7.38186×10⁻⁴ |
| 0.9 | 0.9 | 0.4 | 1.26517×10⁻³ | 1.26514×10⁻³ | 1.26474×10⁻³ | 4.31752×10⁻⁷ | 4.02247×10⁻⁷ | 9.57942×10⁻⁴ |
Table 1: For FZK (2, 2, 2) at and , the second-order approximate solution obtained by NTIM and HPM is compared to the PIA solution.
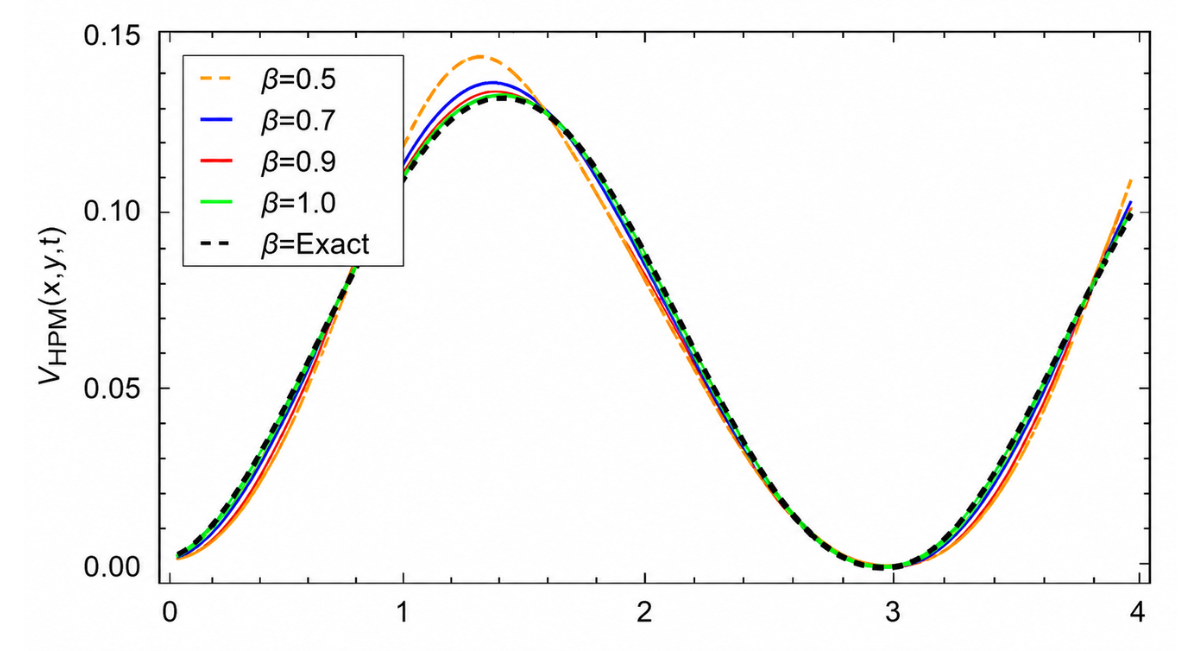
Figure 1: Solution profile of V (γ, ξ, µ) with different β values when ξ = 0.2, λ = 0.1 and µ = 0.01 for problem 1 using HPM.
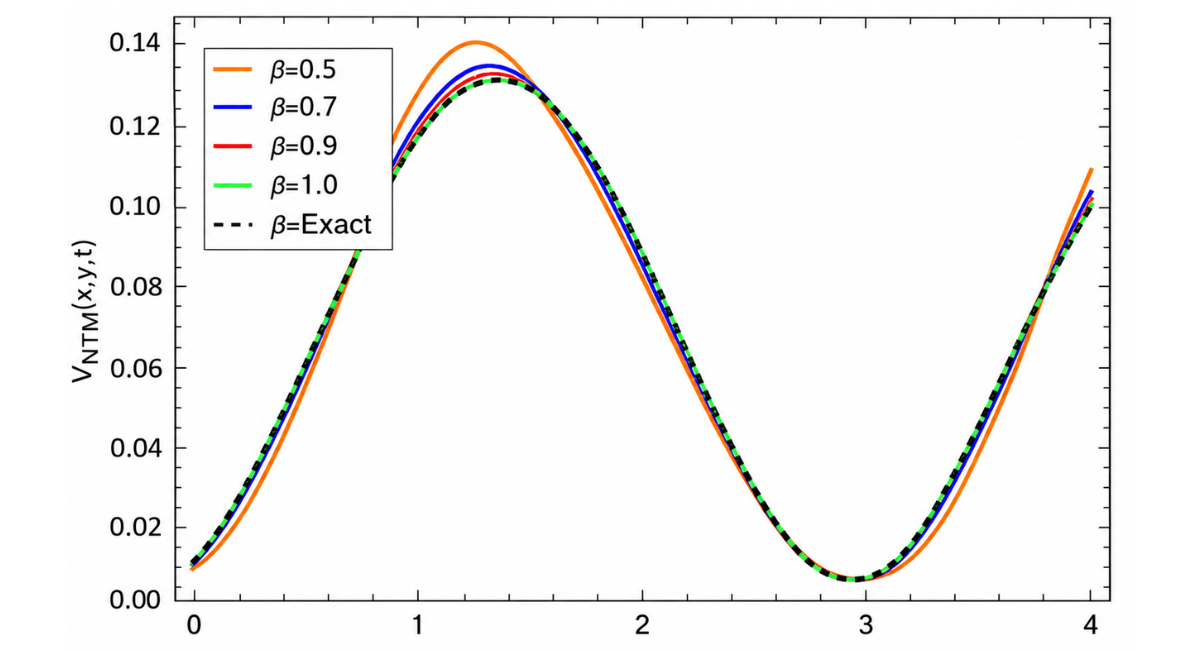
Figure 2: Solution profile of V (γ, ξ, µ) with different β values when ξ = 0.2, λ = 0.1 and µ = 0.01 for problem 1 using NTIM.
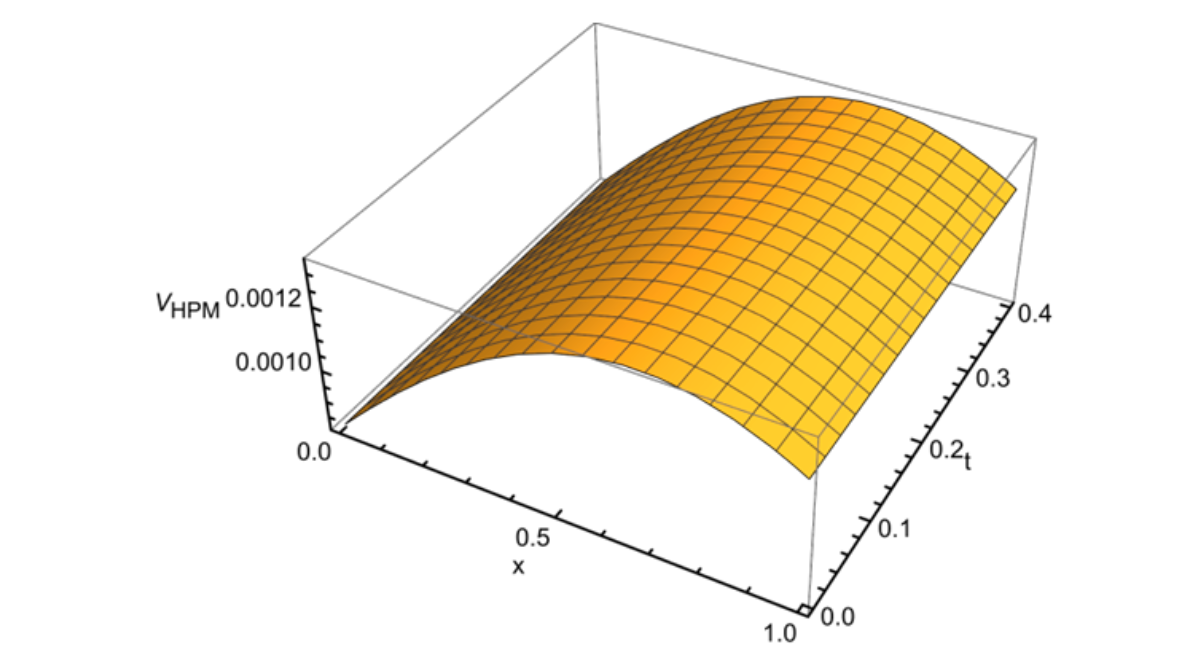
Figure 3: 3D profile of V (γ, ξ, µ) with β = 1, ξ = 0.9, λ = 0.001 for problem 1 using HPM.
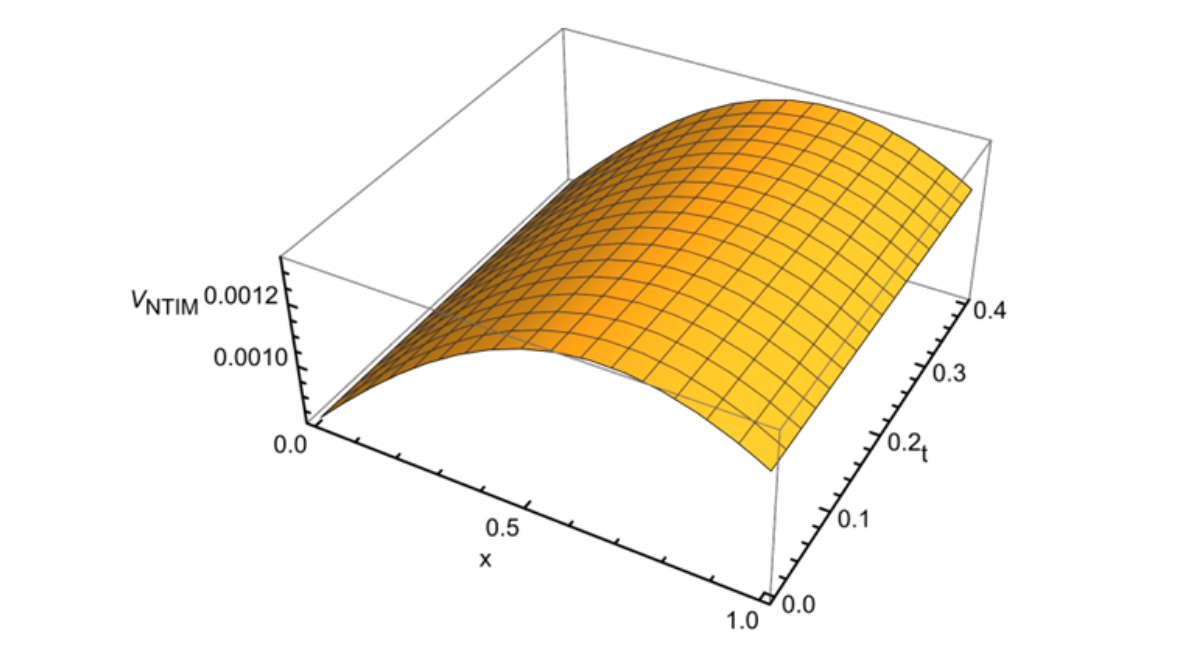
Figure 4: 3D profile of V (γ, ξ, µ) with β = 1, ξ = 0.9, λ = 0.001 for problem 1 using NTIM.
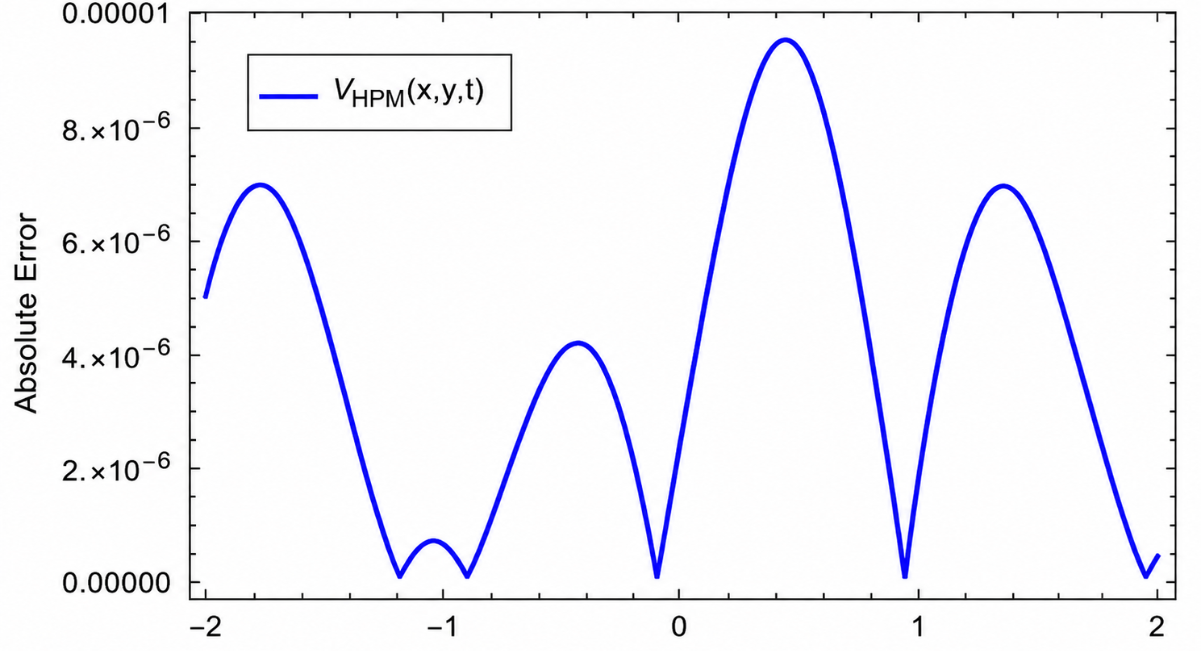
Figure 5: Absolute error graph of V (γ, ξ, µ), when ξ = 0.9, λ = 0.01, β = 1 and µ = 0.01 for problem 1 using HPM.
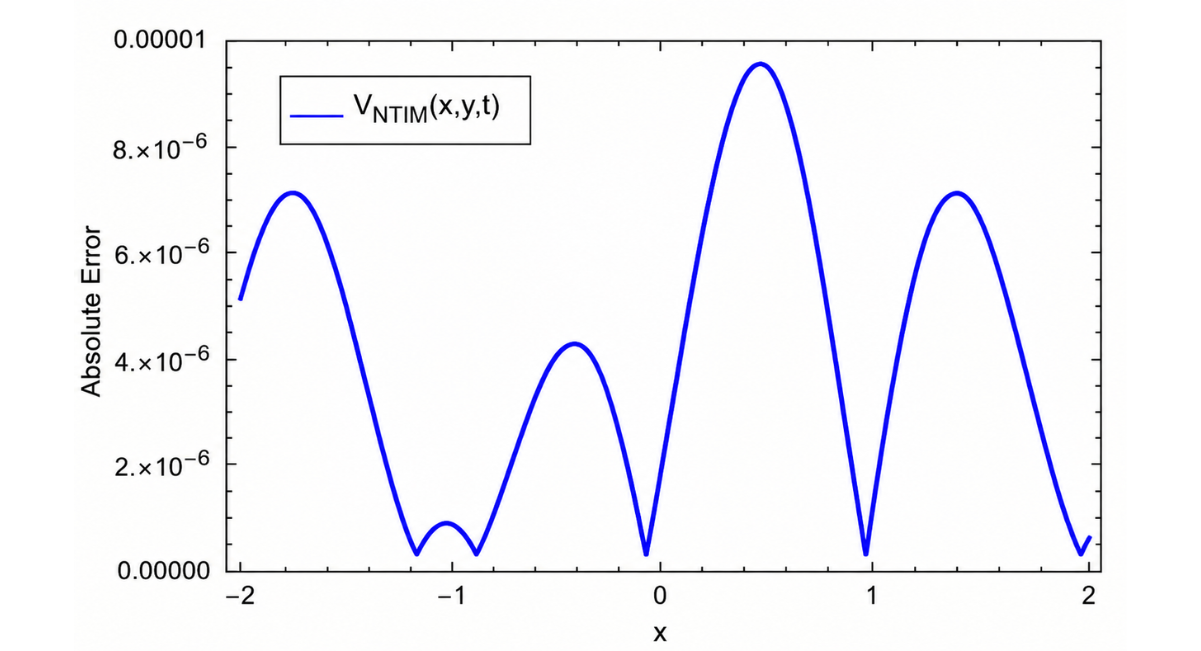
Figure 6: Absolute error graph of V (γ, ξ, µ), when ξ = 0.9, λ = 0.01, β = 1 and µ = 0.01 for problem 1 using NTIM.
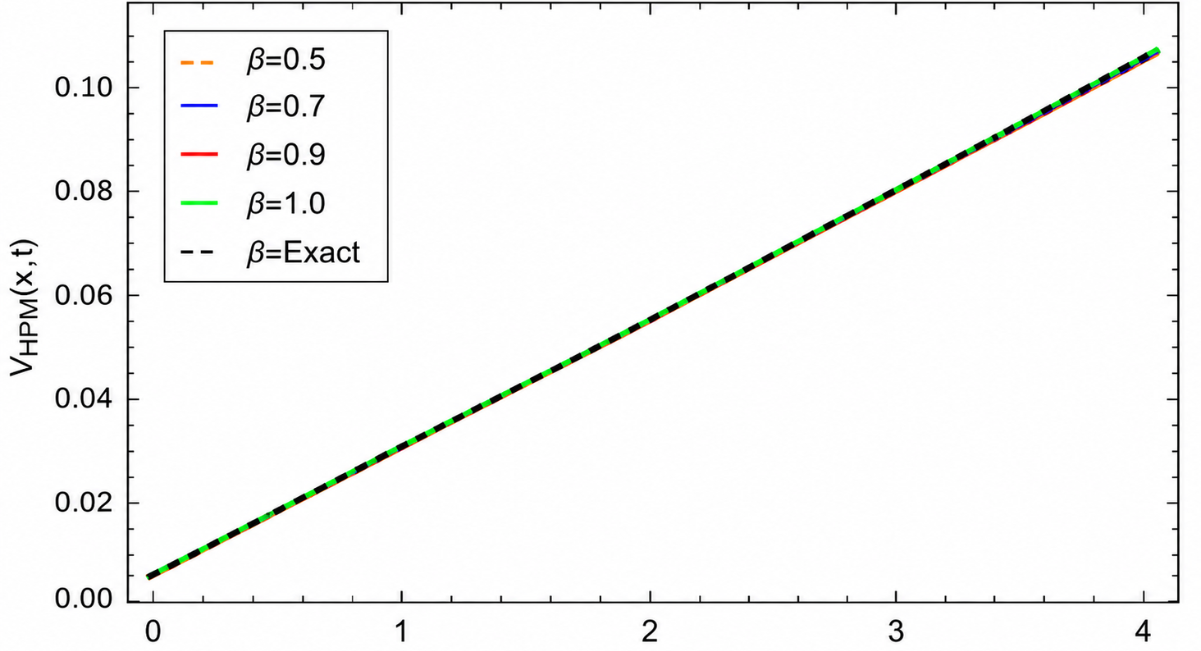
Figure 7: Solution profile of V (γ, ξ, µ) with different β values when ξ = 0.2, λ = 0.1 and µ = 0.1 for problem 2 using HPM.
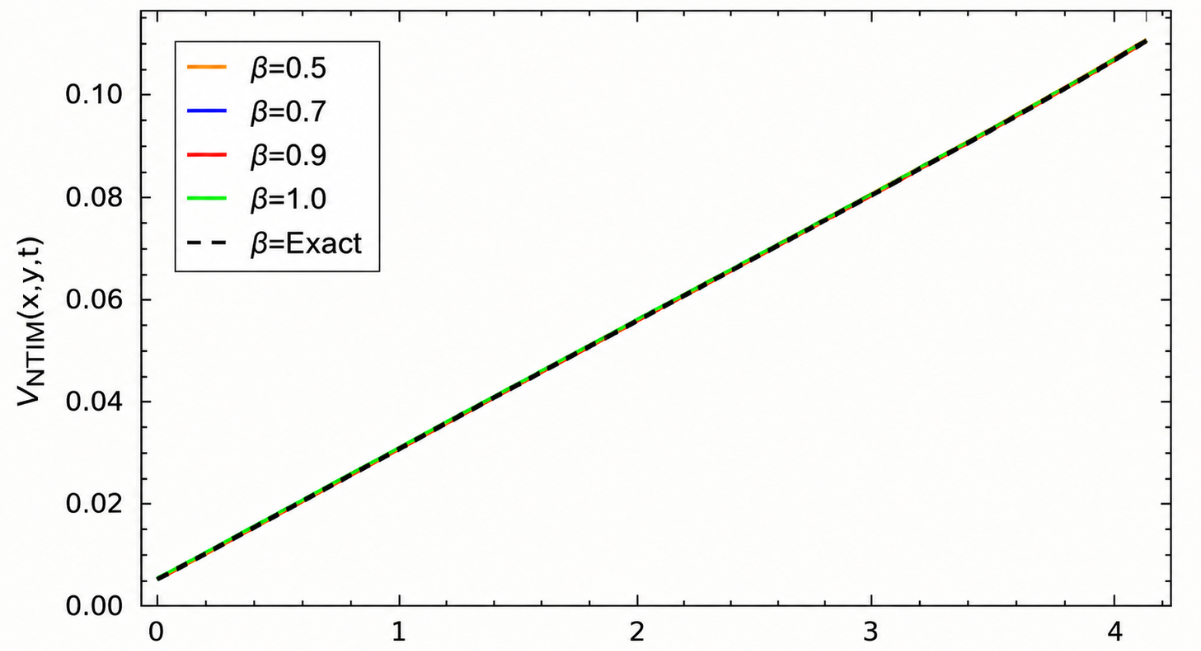
Figure 8: Solution profile of V (γ, ξ, µ) with different β values when ξ = 0.2, λ = 0.1 and µ = 0.1 for problem 2 using NTIM.
| [36] | NTIM Error | HPM Error | ||||||
|---|---|---|---|---|---|---|---|---|
| 0.1 | 0.1 | 0.2 | 5.00092×10⁻⁵ | 5.00092×10⁻⁵ | 5.00091×10⁻⁵ | 4.99592×10⁻⁵ | 4.99486×10⁻⁸ | 4.9952×10⁻⁸ |
| 0.1 | 0.1 | 0.3 | 5.00091×10⁻⁵ | 5.00091×10⁻⁵ | 5.00091×10⁻⁵ | 4.99342×10⁻⁵ | 7.49228×10⁻⁸ | 7.49279×10⁻⁸ |
| 0.1 | 0.1 | 0.4 | 5.00091×10⁻⁵ | 5.00091×10⁻⁵ | 5.00091×10⁻⁵ | 4.99092×10⁻⁵ | 9.98971×10⁻⁸ | 9.99039×10⁻⁸ |
| 0.6 | 0.6 | 0.2 | 3.02004×10⁻⁴ | 3.02004×10⁻⁴ | 3.02003×10⁻⁴ | 3.01953×10⁻⁴ | 5.08887×10⁻⁸ | 5.08988×10⁻⁸ |
| 0.6 | 0.6 | 0.3 | 3.02004×10⁻⁴ | 3.02004×10⁻⁴ | 3.02003×10⁻⁴ | 3.01927×10⁻⁴ | 7.63329×10⁻⁸ | 7.6348×10⁻⁸ |
| 0.6 | 0.6 | 0.4 | 3.02004×10⁻⁴ | 3.02004×10⁻⁴ | 3.02003×10⁻⁴ | 3.01902×10⁻⁴ | 1.01777×10⁻⁷ | 1.01797×10⁻⁷ |
| 0.9 | 0.9 | 0.2 | 4.5678×10⁻⁴ | 4.5678×10⁻⁴ | 4.56780×10⁻⁴ | 4.56728×10⁻⁴ | 5.21165×10⁻⁸ | 5.21228×10⁻⁸ |
| 0.9 | 0.9 | 0.3 | 4.5678×10⁻⁴ | 4.5678×10⁻⁴ | 4.56780×10⁻⁴ | 4.56702×10⁻⁴ | 7.81746×10⁻⁸ | 7.81841×10⁻⁸ |
| 0.9 | 0.9 | 0.4 | 4.5678×10⁻⁴ | 4.5678×10⁻⁴ | 4.56780×10⁻⁴ | 4.56676×10⁻⁴ | 1.04233×10⁻⁷ | 1.04245×10⁻⁷ |
Table 2: At and , the second-order approximation from NTIM and HPM is compared with the VIM solution for FZK (3, 3, 3).
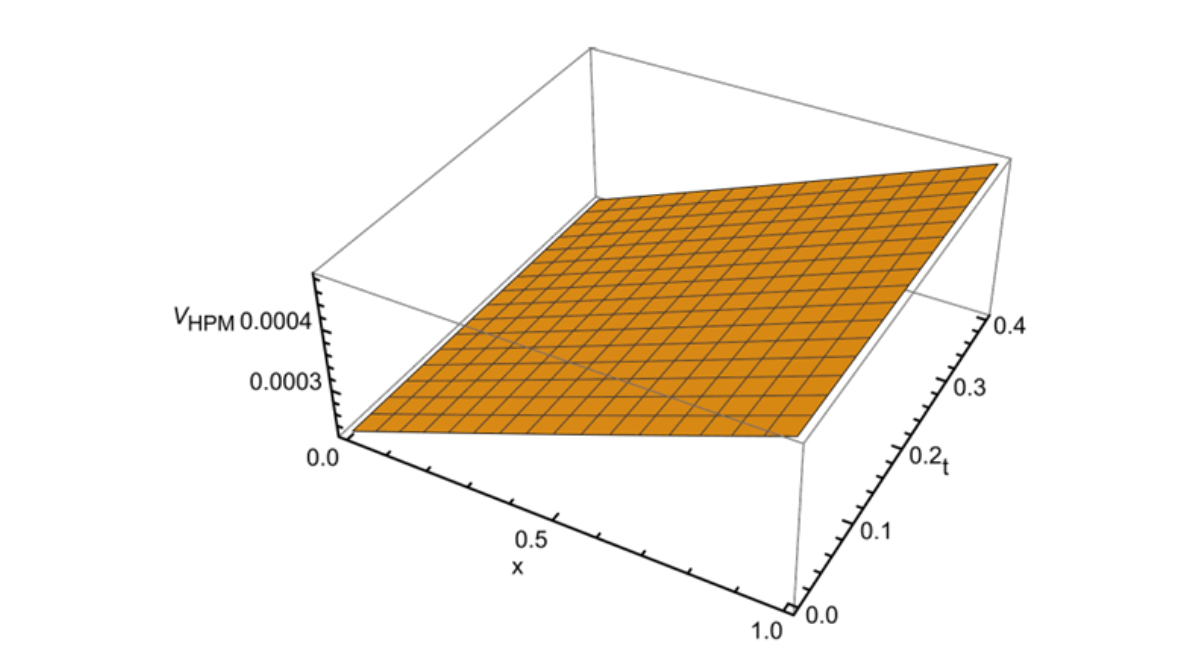
Figure 9: 3D profile of V (γ, ξ, µ) with β = 1, ξ = 0.9, λ = 0.001 for problem 2 using HPM.
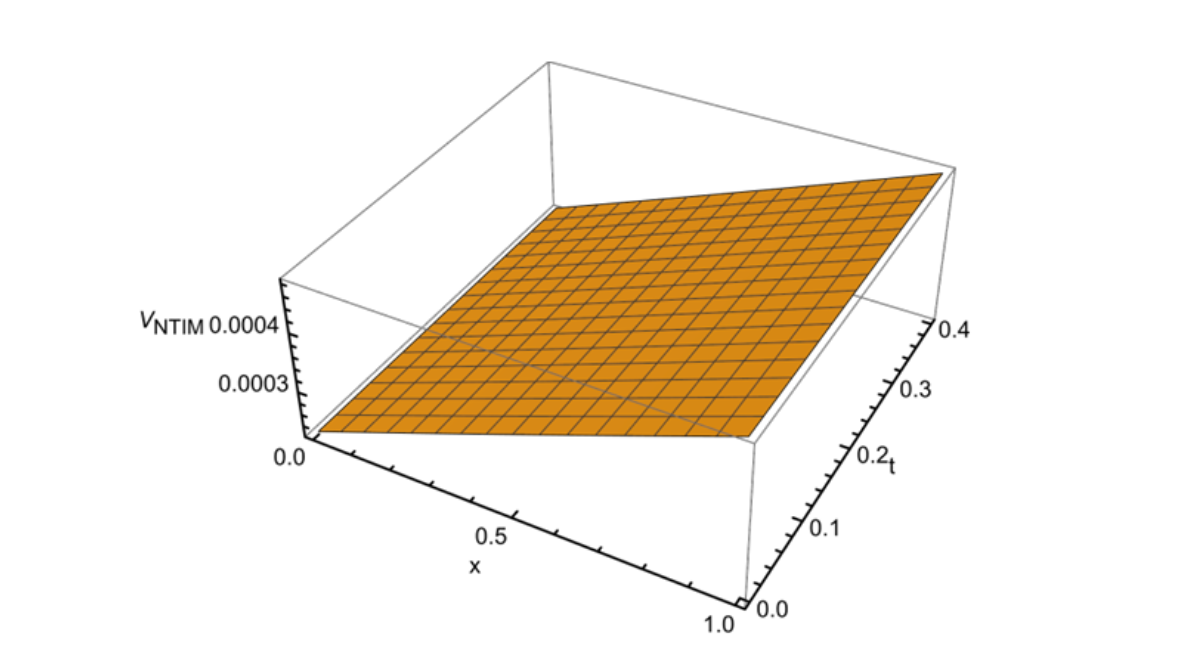
Figure 10: 3D profile of V (γ, ξ, µ) with β = 1, ξ = 0.9, λ = 0.001 for problem 2 using NTIM.
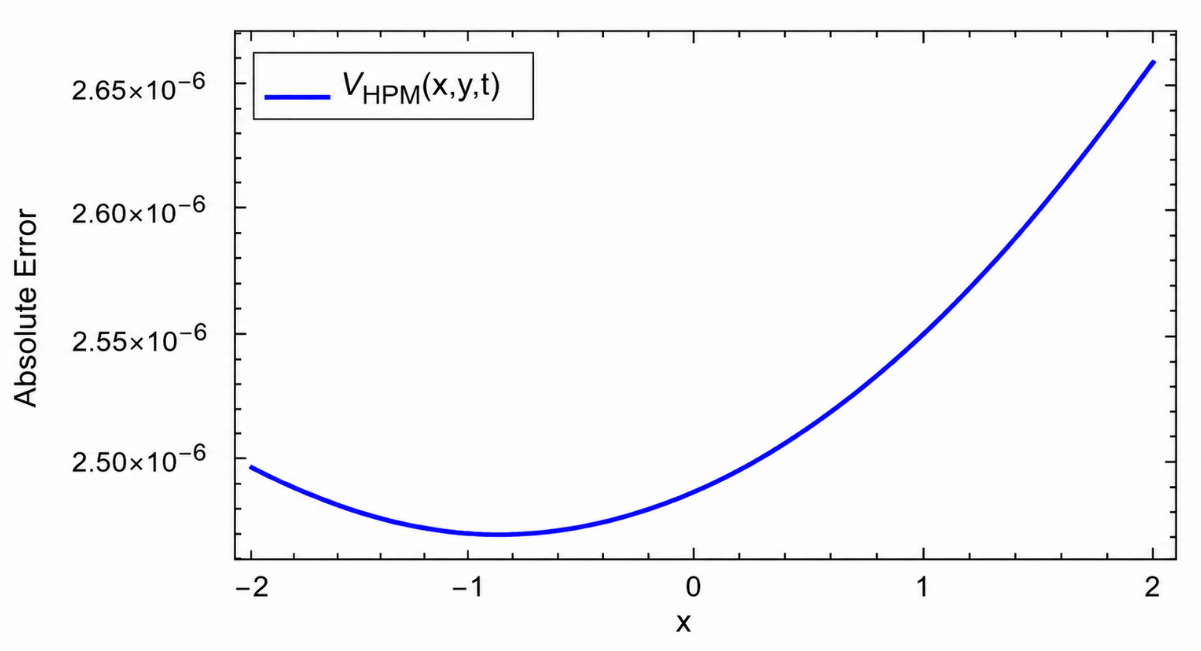
Figure 11: Absolute error graph of V (γ, ξ, µ), when ξ = 0.9, λ = 0.01, β = 1 and µ = 0.1 for problem 2 using HPM.
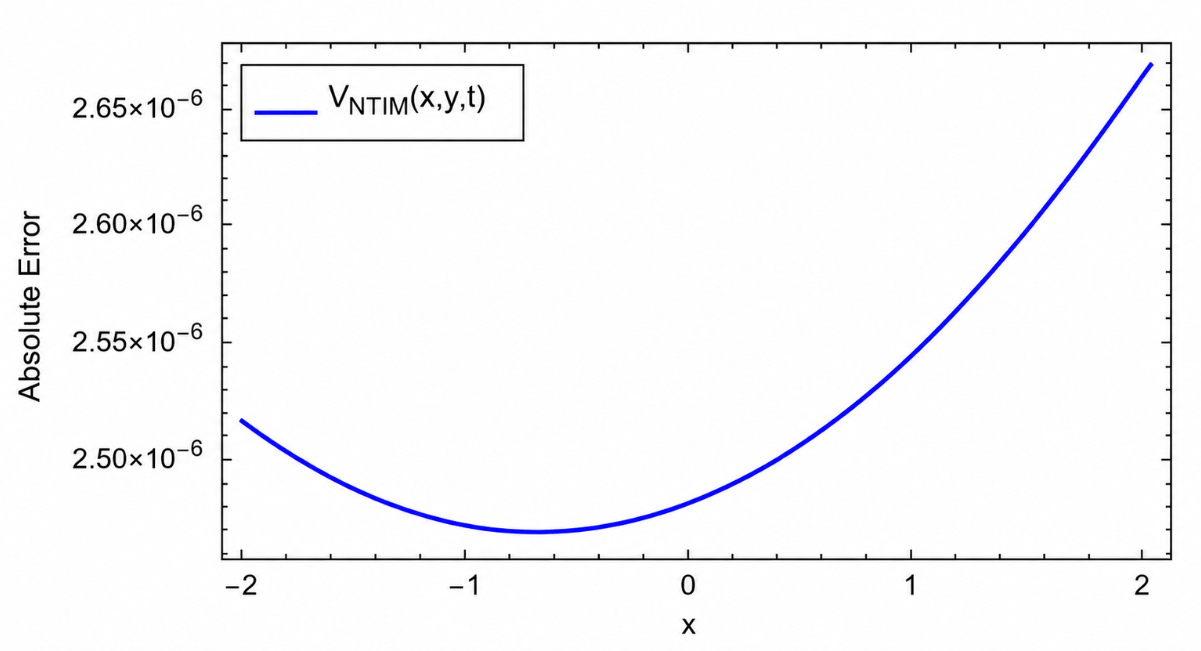
Figure 12: Absolute error graph of V (γ, ξ, µ), when ξ = 0.9, λ = 0.01, β = 1 and µ = 0.1 for problem 2 using NTIM.
CONCLUSION
Second-order NTIM and HPM have produced more promising results in solving FPDE than third-order approximations such as PIA and VIM. The obtained findings demonstrate the efficacy and ease of the proposed methodology for tackling higher-dimensional FPDEs. The data show that the second-order NTIM and HPM solutions perform better, indicating that they are capable of dealing with complicated mathematical problems. The findings highlight the method’s effectiveness and ease in tackling difficulties associated with higher-dimensional FPDEs. The proposed method’s accuracy can be improved by using higher-order approximations, allowing for more precise solution techniques. This technique is consistent with the ongoing search of advanced numerical methodologies for addressing complex mathematical problems encountered in a variety of scientific and engineering disciplines.
REFERENCES
- Fellah ZE, Depollier CL, Fellah M. Application of fractional calculus to the sound waves propagation in rigid porous materials: validation via ultrasonic measurements. Acta Acustica united with Acustica. 2002 ;88(1). [Google Scholar]
- Sebaa N, Fellah ZE, Lauriks W, Depollier C. Application of fractional calculus to ultrasonic wave propagation in human cancellous bone. Signal Processing. 2006;86(10):2668-77. [Crossref] [Google Scholar]
- Meral FC, Royston TJ, Magin R. Fractional calculus in viscoelasticity: an experimental study. Communications in nonlinear science and numerical simulation. 2010;15(4):939-45. [Crossref] [Google Scholar]
- Suárez JI, Vinagre BM, Calderón AJ, Monje CA, Chen YQ. Using fractional calculus for lateral and longitudinal control of autonomous vehicles. InInternational Conference on Computer Aided Systems Theory 2003 (pp. 337-348). Berlin, Heidelberg: Springer Berlin Heidelberg. [Crossref] [Google Scholar]
- Sun Y, Zeng Z, Song J. Existence and uniqueness for the boundary value problems of nonlinear fractional differential equation. Appl. Math. 2017;8(3):312-23. [Crossref] [Google Scholar]
- Meerschaert MM, Scheffler HP, Tadjeran C. Finite difference methods for two-dimensional fractional dispersion equation. Journal of Computational physics. 2006;211(1):249-61. [Crossref] [Google Scholar]
- Metzler R, Klafter J. The restaurant at the end of the random walk: recent developments in the description of anomalous transport by fractional dynamics. Journal of Physics A: Mathematical and General. 2004;37(31):R161-208. [Crossref] [Google Scholar]
- Fractional Differential Equations. Academic Press, New York, NY, USA, 1999.
- Schneider WR, Wyss W. Fractional diffusion and wave equations. Journal of Mathematical Physics. 1989;30(1):134-44. [Crossref] [Google Scholar]
- Momani S. Non-perturbative analytical solutions of the space-and time-fractional Burgers equations. Chaos, Solitons & Fractals. 2006;28(4):930-7. [Crossref] [Google Scholar]
- Erturk VS, Momani S, Odibat Z. Application of generalized differential transform method to multi-order fractional differential equations. Communications in Nonlinear Science and Numerical Simulation. 2008;13(8):1642-54. [Crossref] [Google Scholar]
- Momani S, Odibat Z. Analytical solution of a time-fractional Navier–Stokes equation by Adomian decomposition method. Applied Mathematics and Computation. 2006;177(2):488-94. [Crossref] [Google Scholar]
- Momani S, Odibat Z. Numerical comparison of methods for solving linear differential equations of fractional order. Chaos, Solitons & Fractals. 2007;31(5):1248-55. [Crossref] [Google Scholar]
- Odibat ZM, Momani S. Approximate solutions for boundary value problems of time-fractional wave equation. Applied Mathematics and Computation. 2006;181(1):767-74. [Crossref] [Google Scholar]
- Ray SS. Analytical solution for the space fractional diffusion equation by two-step Adomian decomposition method. Communications in Nonlinear Science and Numerical Simulation. 2009;14(4):1295-306. [Crossref] [Google Scholar]
- Abdulaziz O, Hashim I, Ismail ES. Approximate analytical solution to fractional modified KdV equations. Mathematical and Computer Modelling. 2009;49(1-2):136-45. [Crossref] [Google Scholar]
- HosseinNia SH, Ranjbar A, Momani S. Using an enhanced homotopy perturbation method in fractional differential equations via deforming the linear part. Computers & Mathematics with Applications. 2008;56(12):3138-49. [Crossref] [Google Scholar]
- Abdulaziz O, Hashim I, Momani S. Solving systems of fractional differential equations by homotopy-perturbation method. Physics Letters A. 2008;372(4):451-9. [Crossref] [Google Scholar]
- Abdulaziz O, Hashim I, Momani S. Application of homotopy-perturbation method to fractional IVPs. Journal of Computational and Applied Mathematics. 2008;216(2):574-84. [Crossref] [Google Scholar]
- Song L, Zhang H. Application of homotopy analysis method to fractional KdV–Burgers–Kuramoto equation. Physics Letters A. 2007;367(1-2):88-94. [Crossref] [Google Scholar]
- Hashim I, Abdulaziz O, Momani S. Homotopy analysis method for fractional IVPs. Communications in Nonlinear Science and Numerical Simulation. 2009;14(3):674-84. [Crossref] [Google Scholar]
- Abdulaziz O, Hashim I, Saif A. Series Solutions of Time‐Fractional PDEs by Homotopy Analysis Method. International Journal of Differential Equations. 2008;2008(1):686512. [Crossref] [Google Scholar]
- Abdulaziz O, Hashim I, Chowdhury MS, Zulkifle AK. Assessment of decomposition method for linear and nonlinear fractional differential equations. Far East Journal of Applied Mathematics. 2007;28(1):95-112. [Google Scholar]
- Bataineh AS, Alomari AK, Noorani MS, Hashim I, Nazar R. Series solutions of systems of nonlinear fractional differential equations. Acta Applicandae Mathematicae. 2009;105(2):189-98. [Crossref] [Google Scholar]
- He JH. Approximate analytical solution for seepage flow with fractional derivatives in porous media. Computer methods in applied mechanics and engineering. 1998;167(1-2):57-68. [Crossref] [Google Scholar]
- Neamaty A, Agheli B, Darzi R. Variational iteration method and He’s polynomials for time-fractional partial differential equations. Progress in Fractional Differentiation and Applications. 2015;1(1):47-55. [Google Scholar]
- Eshkuvatov Z. New development of homotopy analysis method for non-linear integro-differential equations with initial value problems. Mathematical modeling and computing. 2022 ;9(4):842-59. [Google Scholar]
- Prakash A, Kaur H. q-homotopy analysis transform method for space and time-fractional KdV-Burgers equation. Nonlinear Sci. Lett. A. 2018;9(1):44-61. [Google Scholar]
- Akinyemi L. q-Homotopy analysis method for solving the seventh-order time-fractional Lax’s Korteweg–de Vries and Sawada–Kotera equations: L. Akinyemi. Computational and Applied Mathematics. 2019;38(4):191. [Crossref] [Google Scholar]
- Tatari M, Dehghan M, Razzaghi M. Application of the Adomian decomposition method for the Fokker–Planck equation. Mathematical and Computer Modelling. 2007;45(5-6):639-50. [Crossref] [Google Scholar]
- Wazwaz AM. A reliable modification of Adomian decomposition method. Applied mathematics and computation. 1999;102(1):77-86. [Crossref] [Google Scholar]
- Ali N, Nawaz R, Zada L, Mouldi A, Bouzgarrou SM, Sene N. Analytical approximate solution of the fractional order biological population model by using natural transform. Journal of Nanomaterials. 2022;2022(1):6703086. [Crossref] [Google Scholar]
- Rehman SU, Nawaz R, Zia F, Fewster-Young N, Ali AH. A comparative analysis of Noyes-Field model for the non-linear Belousov–Zhabotinsky reaction using two reliable techniques. Alexandria Engineering Journal. 2024;93:259-79. [Crossref] [Google Scholar]
- Bhalekar S, Daftardar-Gejji V. Convergence of the new iterative method. International journal of differential equations. 2011;2011(1):989065. [Crossref] [Google Scholar]
- He JH. Homotopy perturbation method: a new nonlinear analytical technique. Applied Mathematics and computation. 2003;135(1):73-9. [Crossref] [Google Scholar]
- Nawaz R, Zada L, Khattak A, Jibran M, Khan A. Optimum solutions of fractional order Zakharov–Kuznetsov equations. Complexity. 2019;2019(1):1741958. [Crossref] [Google Scholar]
Article Processing Timeline
| 2-5 Days | Initial Quality & Plagiarism Check |
| 25-35 Days |
Peer Review Feedback |
| 45-60 Days | Total article processing time |
Why Publish with us?
Ethics & Policies
Editorial & Management
Useful Links
Journal Highlights
Open Access Journals
Journal Flyer